A new humanoid robot designed to support crop breeding has been unveiled in Beijing, highlighting the growing use of embodied AI in agriculture.
The humanoid robot called GEAIR 2.0 combines robotics, artificial intelligence and biotechnology to automate hybrid pollination for crop breeding, a labor-intensive step in the process. The humanoid robot can identify flowers, navigate around plants and perform pollination autonomously, allowing it to work for extended periods without continuous human supervision.
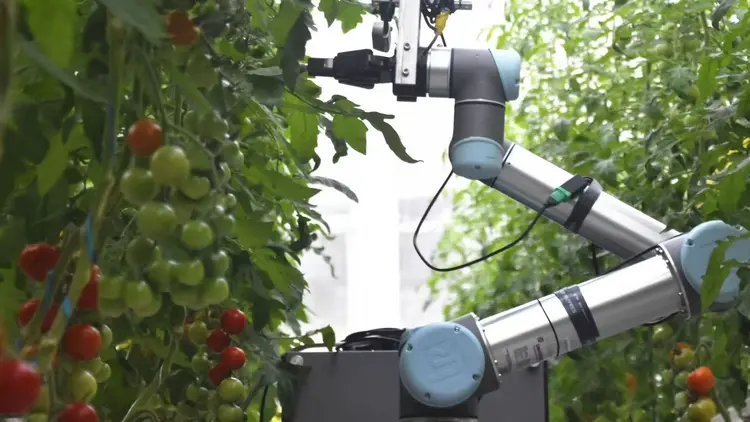
The upgraded robot uses two arms instead of the flexible single-arm system used previously. This allows it to maneuver more effectively around leaves and branches and adapt to changing conditions inside crops. Its stigma-recognition accuracy (its ability to identify a flower’s female reproductive organ) has also improved from 85 percent to 92.8 percent.
During its launch in Beijing, GEAIR 2.0 demonstrated tomato pollination by using one hand to hold a pollen tube and the other to operate a pollination brush. The robot completed each pollination in less than 10 seconds, while a single dip of the brush into pollen could support about 50 pollinations, as reported by China Daily.
The system’s name refers to Genome Editing combined with AI-based Robotics. Researchers use gene editing to create male-sterile plants with exposed stigmas, making the reproductive structures easier for the robot to identify and access.
The approach, described as “crop-robot co-design,” was detailed in a 2025 study published in Cell. Researchers found that automated tomato cross-pollination could achieve efficiency comparable to manual methods and later extended the approach to soybean.
The developers say automating pollination could reduce the need for manual labor, lower breeding costs, and improve the efficiency of hybrid breeding. Robots could also perform repetitive tasks for longer periods and operate under varying environmental conditions, potentially making them useful for large-scale crop breeding operations.
In this process, the researchers first modify the plants to expose the stigma, removing the need for workers to manually open petals and giving the robot easier access to the reproductive structure.
The robot must then navigate through dense crops, avoid branches and leaves, and locate the needle-sized stigma with enough precision to complete pollination. This allows it to perform repetitive breeding tasks for longer periods than human workers, including during different times of day and under varying weather conditions.
According to experts, hybrid pollination is physically demanding and must often be completed within a narrow time window. With this new invention, Robots could let farmers manage the process while reducing the manual labor required, thereby increasing Agricultural crop production and putting an end to food insecurity around the world.