MIT engineers have built a paper-thin swimming robot powered by living muscle cells that respond to flashes of light, allowing it to swim and steer through water. The breakthrough could pave the way for tiny, self-healing biological robots capable of exploring fragile environments that ordinary machines cannot safely navigate.
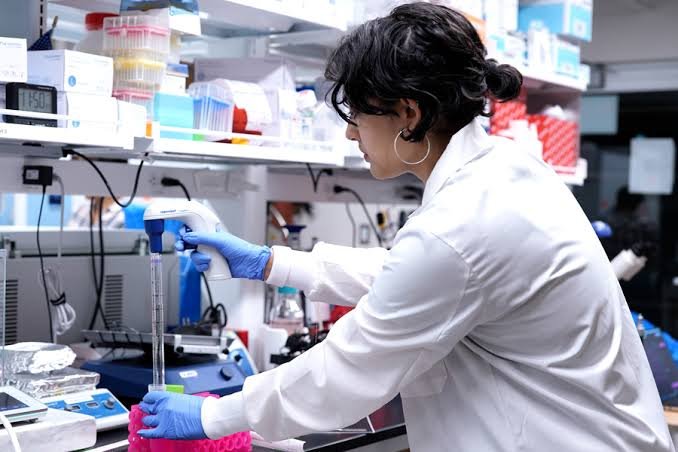
A swimming robot does not necessarily need a bulky motor or powerful mechanical parts to move through water. MIT researchers have demonstrated that a single, carefully engineered layer of living muscle cells can generate enough force to propel a tiny robot forward.
The engineers developed an extremely thin swimming robot that uses living muscle tissue to move its fins. Described in a new study published in Advanced Functional Materials, the device has a flexible gel framework roughly the length and width of a stick of gum. The gel forms two fins, each coated with a layer of muscle cells far thinner than a human hair. These cells have been genetically modified to contract when exposed to light.
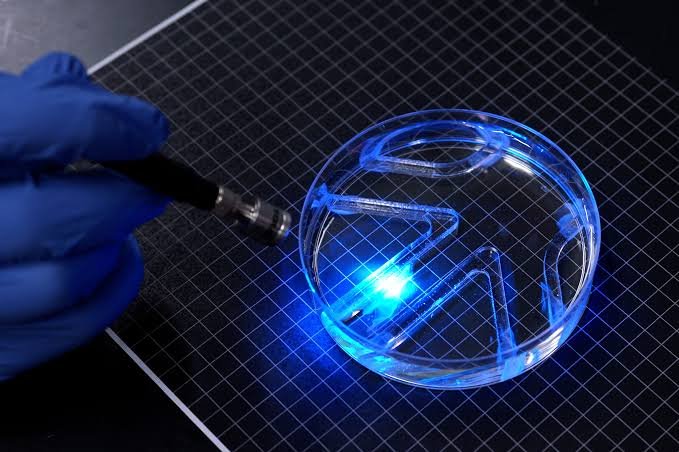
By directing light onto either fin, the researchers can trigger muscle contractions that make the fin flap and push the robot through water. Adjusting which fin receives light and how frequently it is illuminated allows the team to control both its speed and direction.
In experiments, the remarkably thin robot successfully swam and turned through a simple underwater maze. At maximum speed, it covered approximately four times its body length per minute. Although that is much slower than an Olympic swimmer, who can travel up to 65 body lengths per minute, it is comparable to the swimming pace of a cow shark moving leisurely through the ocean.
”It takes a lot of force to move through water versus air,” says study author Ritu Raman, associate professor of mechanical engineering at MIT. “The robot’s quite strong, given its size. “
A New Generation of Robots Powered by Living Muscle
The device represents the first demonstration of a very thin, two-dimensional robot that can move from place to place using living muscle tissue.
Most existing biohybrid robots rely on relatively large, three-dimensional structures made from laboratory-grown skeletal muscle. Producing these structures typically requires millions of cells. Raman explains that thinner designs could reduce manufacturing costs while potentially improving movement efficiency.
”Currently, biohybrid robots from our group and others’ are built from bulky, 3D chunks of lab-grown skeletal muscle that require millions of cells to fabricate,” – says Raman, who notes that thinner, less bulky designs such as the team’s new bot could be cheaper to build and could move more efficiently.
“We believe that biohybrid robots powered by living muscle could one day perform delicate jobs like exploring environments too fragile or unpredictable for conventional hardware, because living tissue is soft, responsive to its surroundings, and can heal itself.”
The MIT research team also included first author Maheera Bawa, along with Arielle Berman, Laura Schwendeman, Ferdows Afghah, and Seanbiron Johnson.
From Artificial Muscle to a Swimming Robot
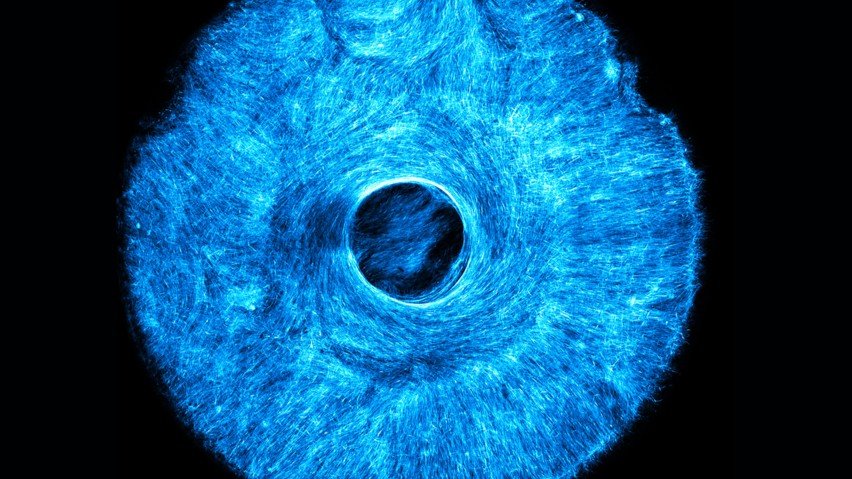
The new swimming robot builds on an earlier achievement by Raman’s laboratory. Last year, the researchers created an artificial muscle disk inspired by the human iris, demonstrating how a thin layer of living cells could produce precisely controlled movements.
Raman’s research team grew the artificial muscle tissue using a simple but unique “stamping” approach they developed. The first step was 3D-printing a small, handheld stamp patterned with microscopic grooves, each as small as a single cell. They then pressed the stamp into a soft hydrogel and seeded the resulting grooves with live muscle cells. (Before pressing the stamp into the hydrogel mat, they coated the bottom of the stamp with a protein that helped imprint the pattern evenly into the gel and peel away without sticking or tearing). The cells grew along these grooves within the hydrogel, forming fibers.
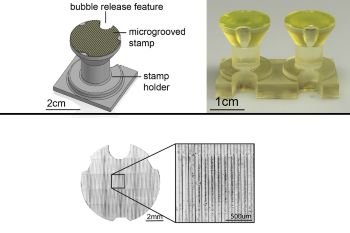
Researchers 3D printed a small, handheld stamp (top images). When pressed into a soft hydrogel and seeded the resulting grooves with real muscle cells, the stamp enabled growth of cells in one direction. Image: Courtesy of the researchers
When illuminated, the muscle tissue contracted in different directions, causing the disk to stretch and compress. Its movements resembled the way the iris of the human eye changes shape as the pupil expands or narrow.